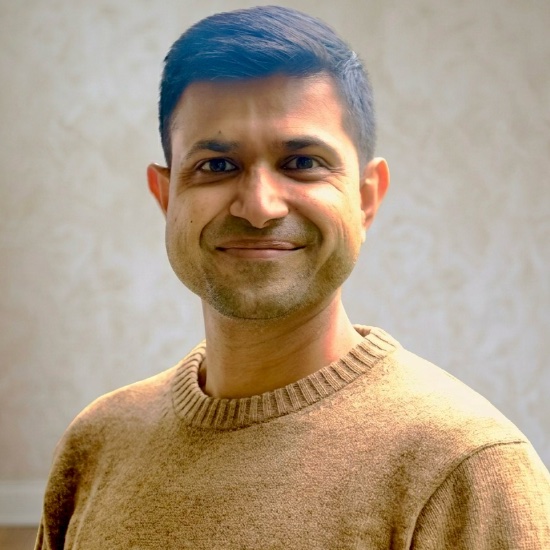
Hello! I'm Adrit.
Hekavor's co-founder, working to augment physicians and help patients reach accurate diagnoses sooner. Happiest with complex, multidisciplinary systems, from autonomous‑vehicle LiDAR to surgical robots.
Work
Hekavor's assistant, Mari, asks physician-quality questions from the patient before their appointment. It then generates a chart-ready note with working diagnoses for the physician to review. This saves the physician 5–15 minutes and leads to a deeper appointment with the patient. The patient feels heard and no details are missed, leading to potentially better outcomes.
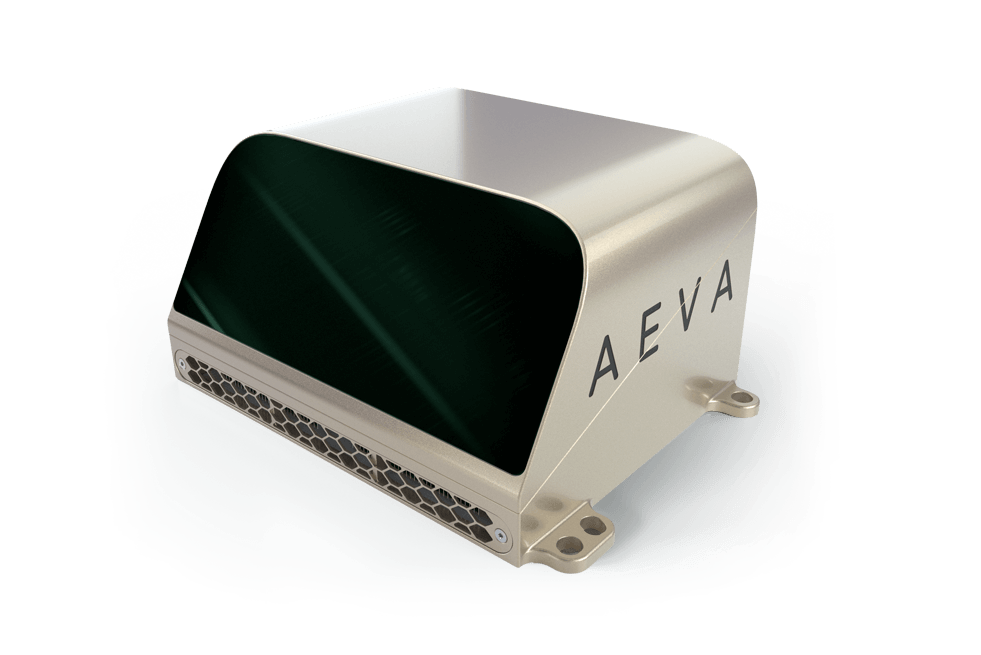
Led the Aeva Omni project with LGIT. Managed simulations, scanner hardware and controls, and was part of the product design team. Worked closely with business development and sales to engage new and existing customers in the automotive, industrial, defense and aerospace verticals.
Managed and worked on scanner hardware and controls. Designed, developed and brought into production high-speed, high-precision actuators, including drive and sense electronics, that are automotive grade but consumer cost.
DaVinci surgical system
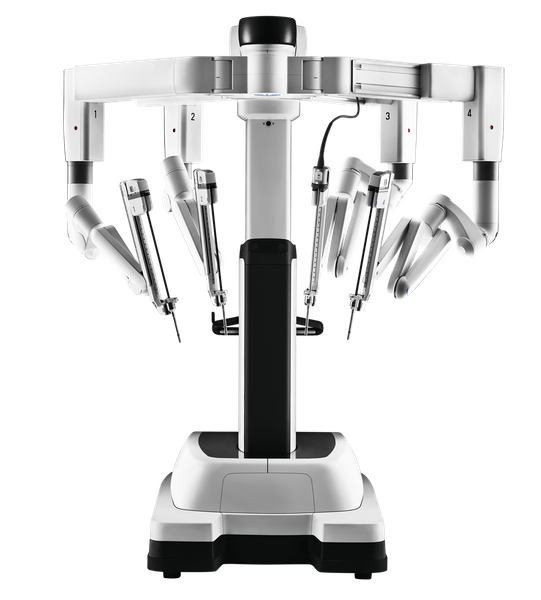
Managed the New Product Design team for Advanced Energy Instruments. The team designs Vessel Sealers that are used in hundreds of thousands of procedures per year. This technology works by delivering closed-loop RF energy and precisely controlled compression to seal blood vessels, which is a very critical operating step. Additionally, I worked on IP, budgets and hiring for the team.
SynchroSeal
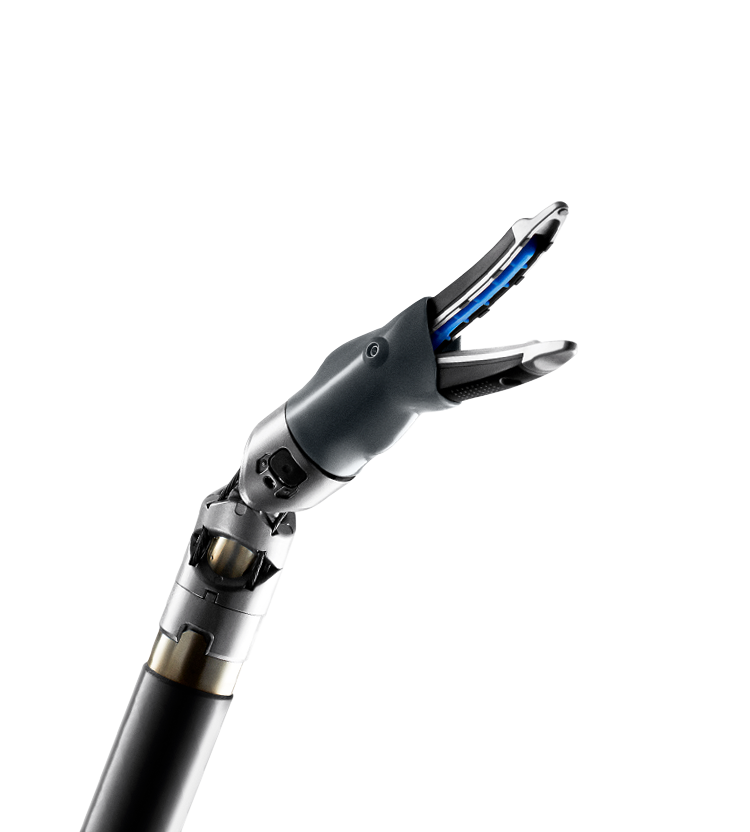
SynchroSeal is a novel surgical instrument that uses RF energy for both cutting (usually a mechanical blade) and sealing vessels. It is the world's first RF cutting and sealing instrument with a 'wrist'. I co-developed novel control algorithms and mechanical wrist components that made this product viable.
DaVinci X robot
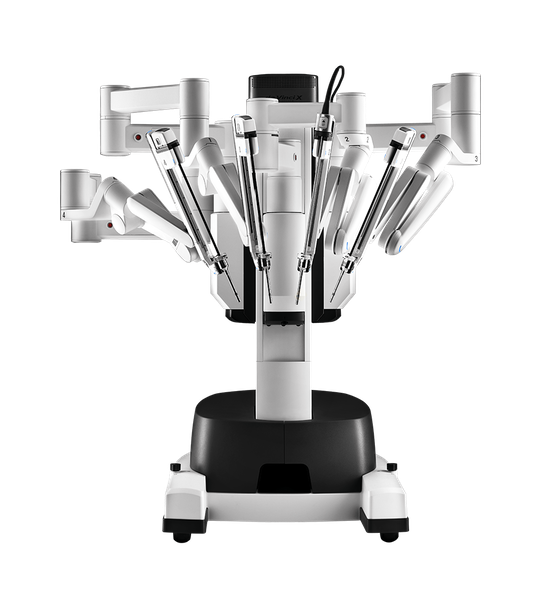
Worked on key components for the joint and encoder of arm 2 of the DaVinci X robot, which launched in mid 2017. Found a solution for a joint issue discovered late in the design cycle and fixed encoder linearity problems. Also redesigned parts for manufacturability and ran V&V testing.
Consumables and automation
Owned the design of all disposable consumables, and the automation that dispenses, handles, stores and configures them. Recruited the hardware engineering team and kept contributing to the design of consumables and automation components.
Automation line
Architected high-throughput pick-and-place automation lines for the consumables used in diagnostic tests, sized for near-term growth but flexible enough to change without major reinvestment. Designed all the end-effectors on the delta robots in this video.
Minilab
Part of the original group that designed the Minilab diagnostic device. Responsible for the motion platform, chassis, enclosure and several fluid handling systems that handled 2-40 uL at sub 5% CV. Also designed injection-molded disposables for reagents and fluids.
Internships
Improved the li-ion cell simulation model for extreme temperature and power demand, and added support for cells with different chemistries in one pack model.
Designed a chassis concept for a three-wheeled vehicle with a swappable battery pack, and built a simulation that optimizes pack size and chemistry for cost and range.
Developed an Ansys algorithm that iterates over parametric geometries to find the lowest-weight part that meets the strength criteria.
Designed and built a go-no-go gauge for a high-failure component, and used a Monte-Carlo stack-up analysis to find parts that needed tighter tolerances.
Education
 MS Mechanical Engineering
Sep 2009 – Jun 2011
Depth in Mechatronics and Design Methodology. Teaching assistant for ME310 - Design Methodology, dynamics and digital computational photography.
 BS Mechanical Engineering
Aug 2005 – Dec 2008
Won 1st place for the senior design project, a hybrid Formula SAE race car. President's Undergraduate Research Scholarship awardee.
Projects
An RC boat for ME218C, the third class in the mechatronics sequence. The electronics, hardware, hull and powertrain were designed and built in 3 weeks. The project used wireless communication over Xbee.
As the video shows, the team took the competition a little too seriously. Ours is the speedy boat doing the bullying!
An autonomous basketball-playing robot for ME218B, the second mechatronics class. The robot used sensors to detect pulsing IR light and features on the playing surface to navigate the court. A PID-controlled flywheel changed speed with the distance from the hoop to launch the balls. A state-machine control scheme ran the robot.
Panasonic, which makes Li-ion batteries, wanted to explore EV concepts for future urban environments. The team built a functional single-passenger EV prototype that folded to reduce its parking footprint. A canopy-style door made it easy to enter and exit. The design assumed autonomous driving would be the norm, so the interior had no steering wheel or shift knob.
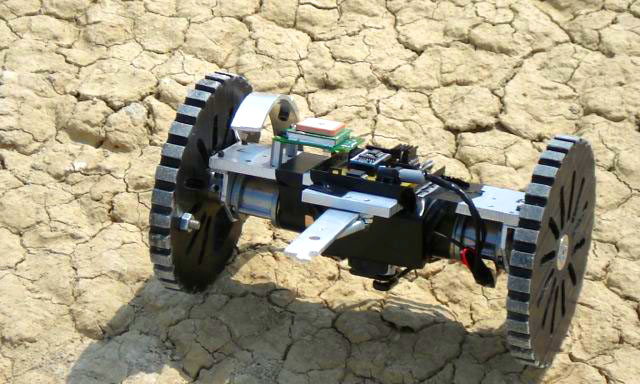
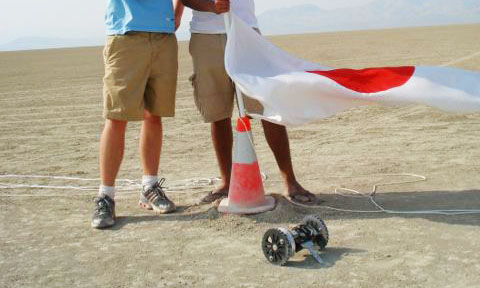
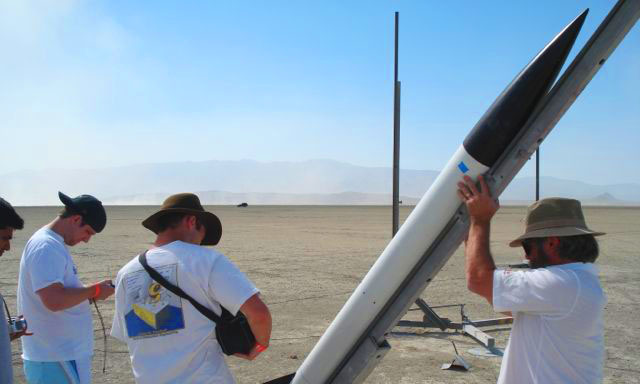
Every year, in the Black Rock Desert in Nevada, college students gather to have their tiny rovers shot up to 10,000 ft on rockets and dropped. The objective is to return to earth in one piece and then navigate to a pre-determined coordinate using GPS. The aim is to develop very cheap, robust rovers that can be deployed to planets like Mars. The Georgia Tech research group took part every year. Took part for 2 years, working on most of the mechanical design, parachute deployment, motors and wheels.
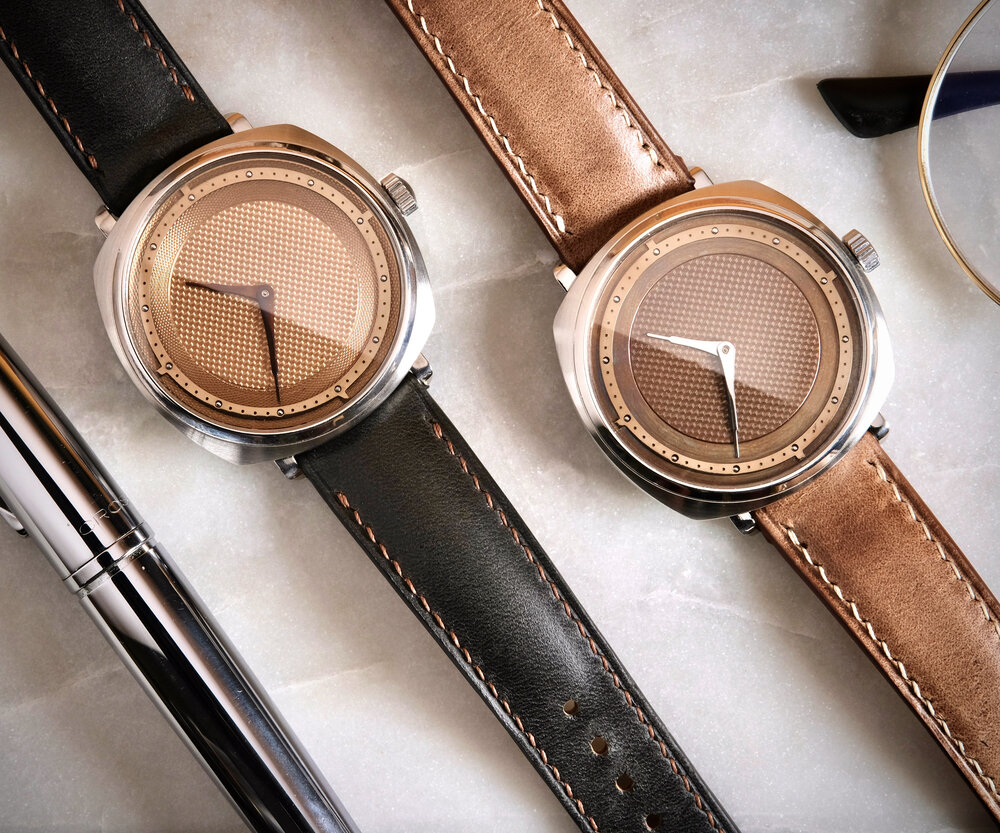
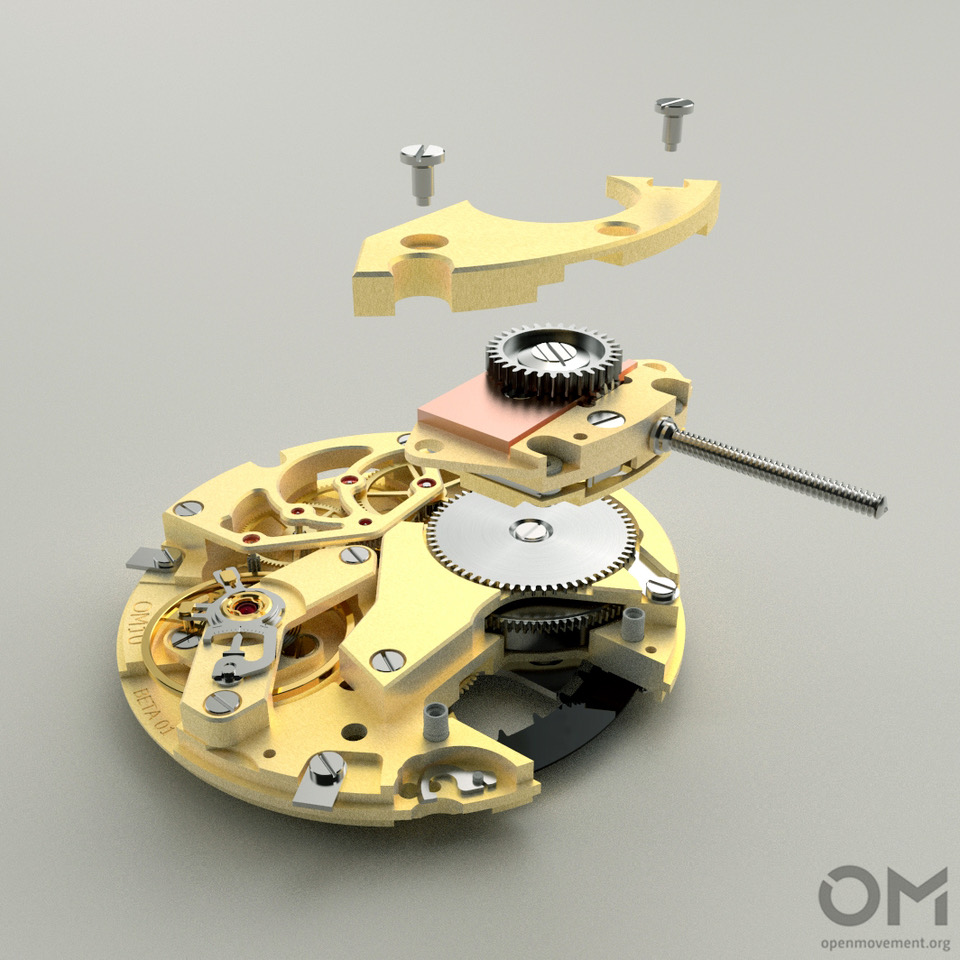
Designed and made a few mechanical watches over the last few years. Member of openmovement.org, an open-source watch movement design organization.
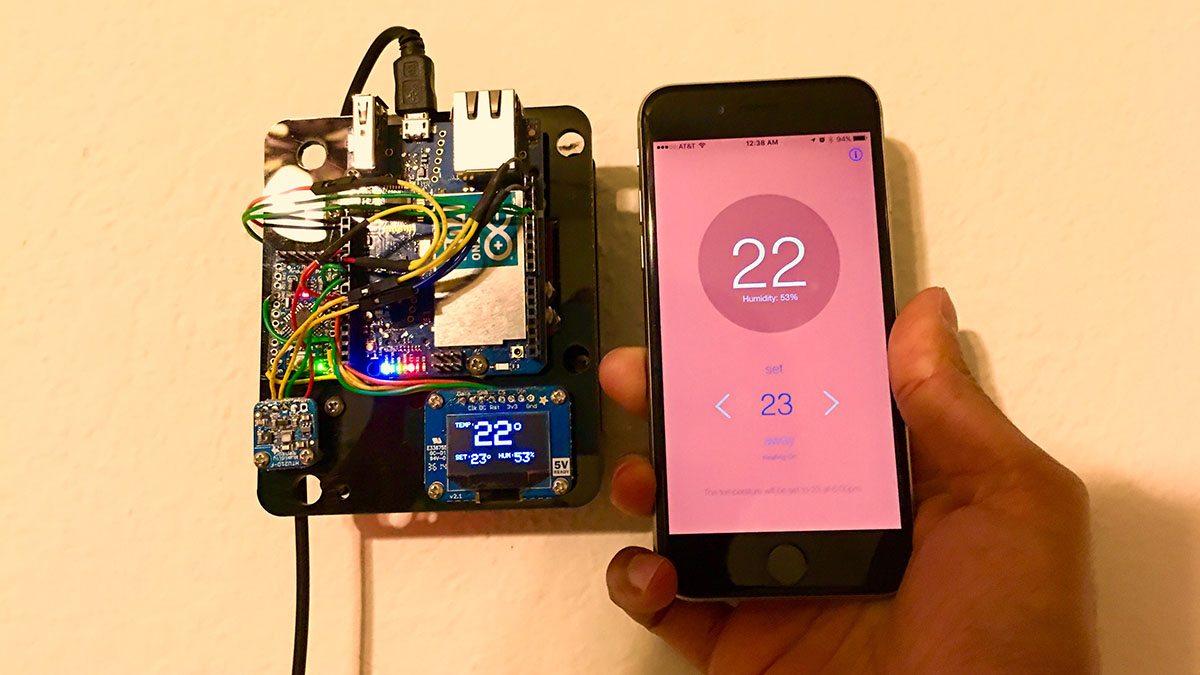
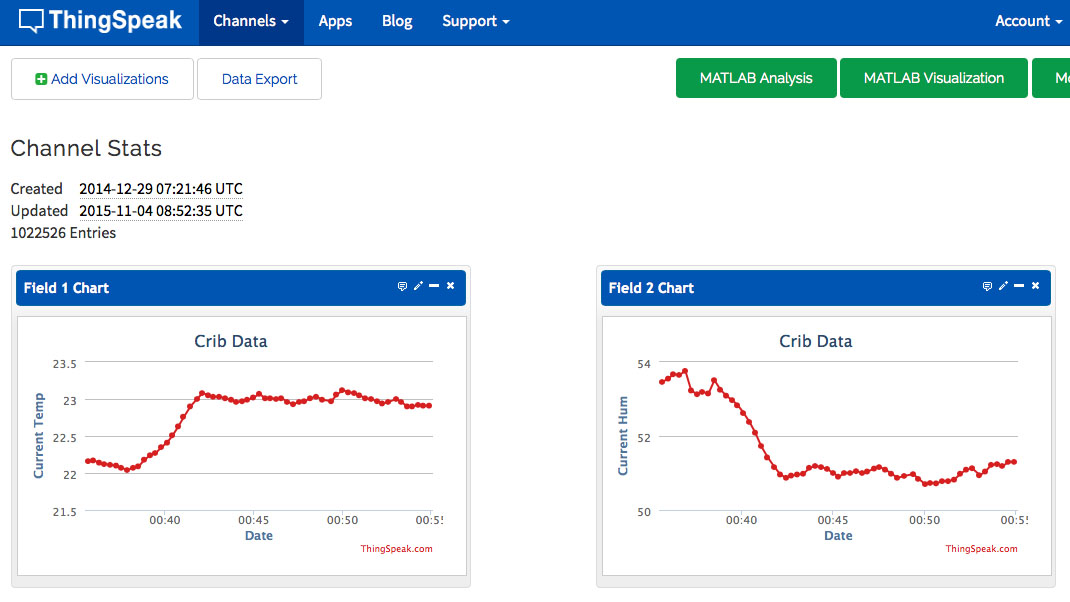
A Nest would not install on the old thermostat and heater in the apartment. The thermostat is literally a mechanical thermocouple that connects the lines to turn on the heater. So, a custom thermostat: an Arduino Yun (WiFi), a high-load relay and a temperature sensor. The Arduino pushes and pulls temperature data to ThingSpeak, a web service with a very simple API for sensor data. The iPhone app also pushes set-point data to the ThingSpeak channel. The Arduino reads it to turn the heater on or off. The heater can be controlled from anywhere.
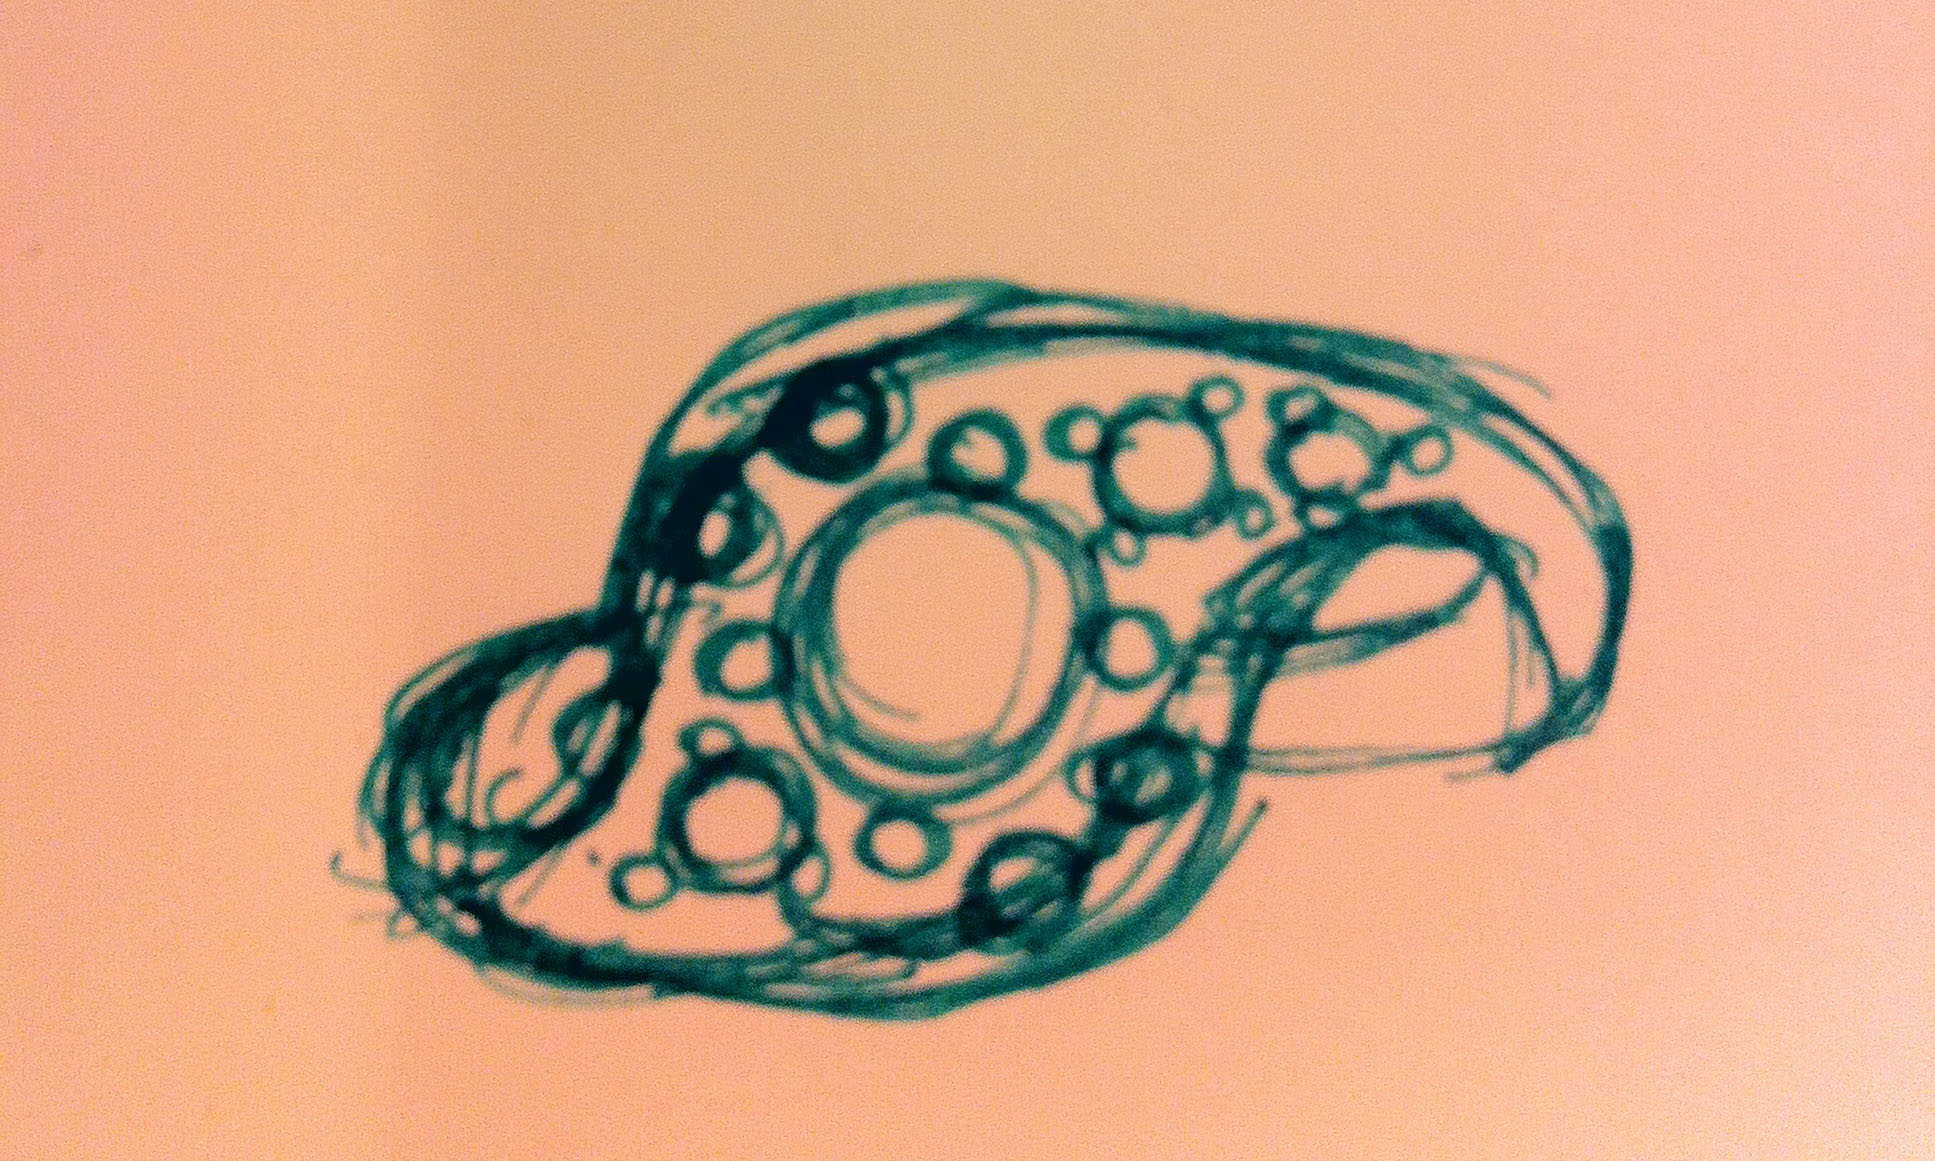
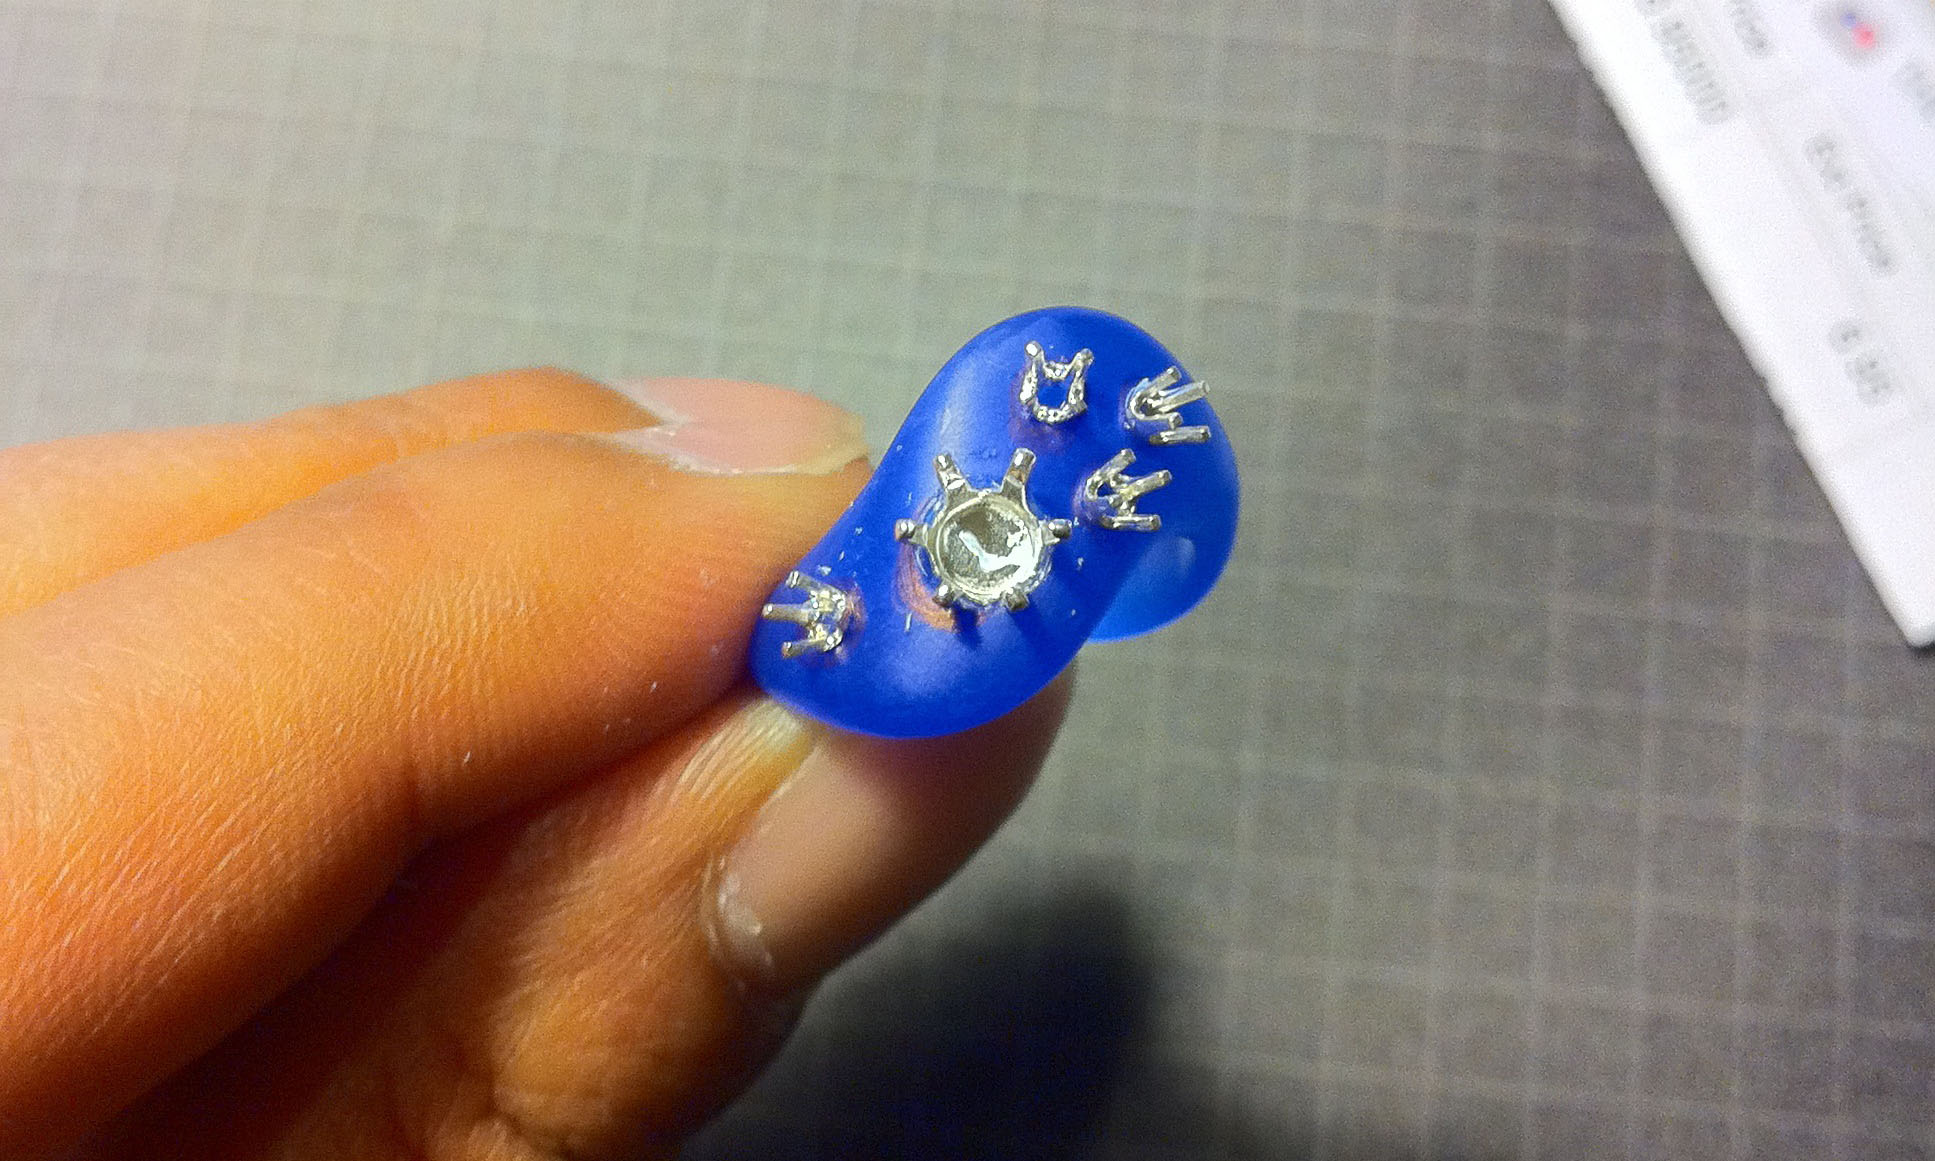
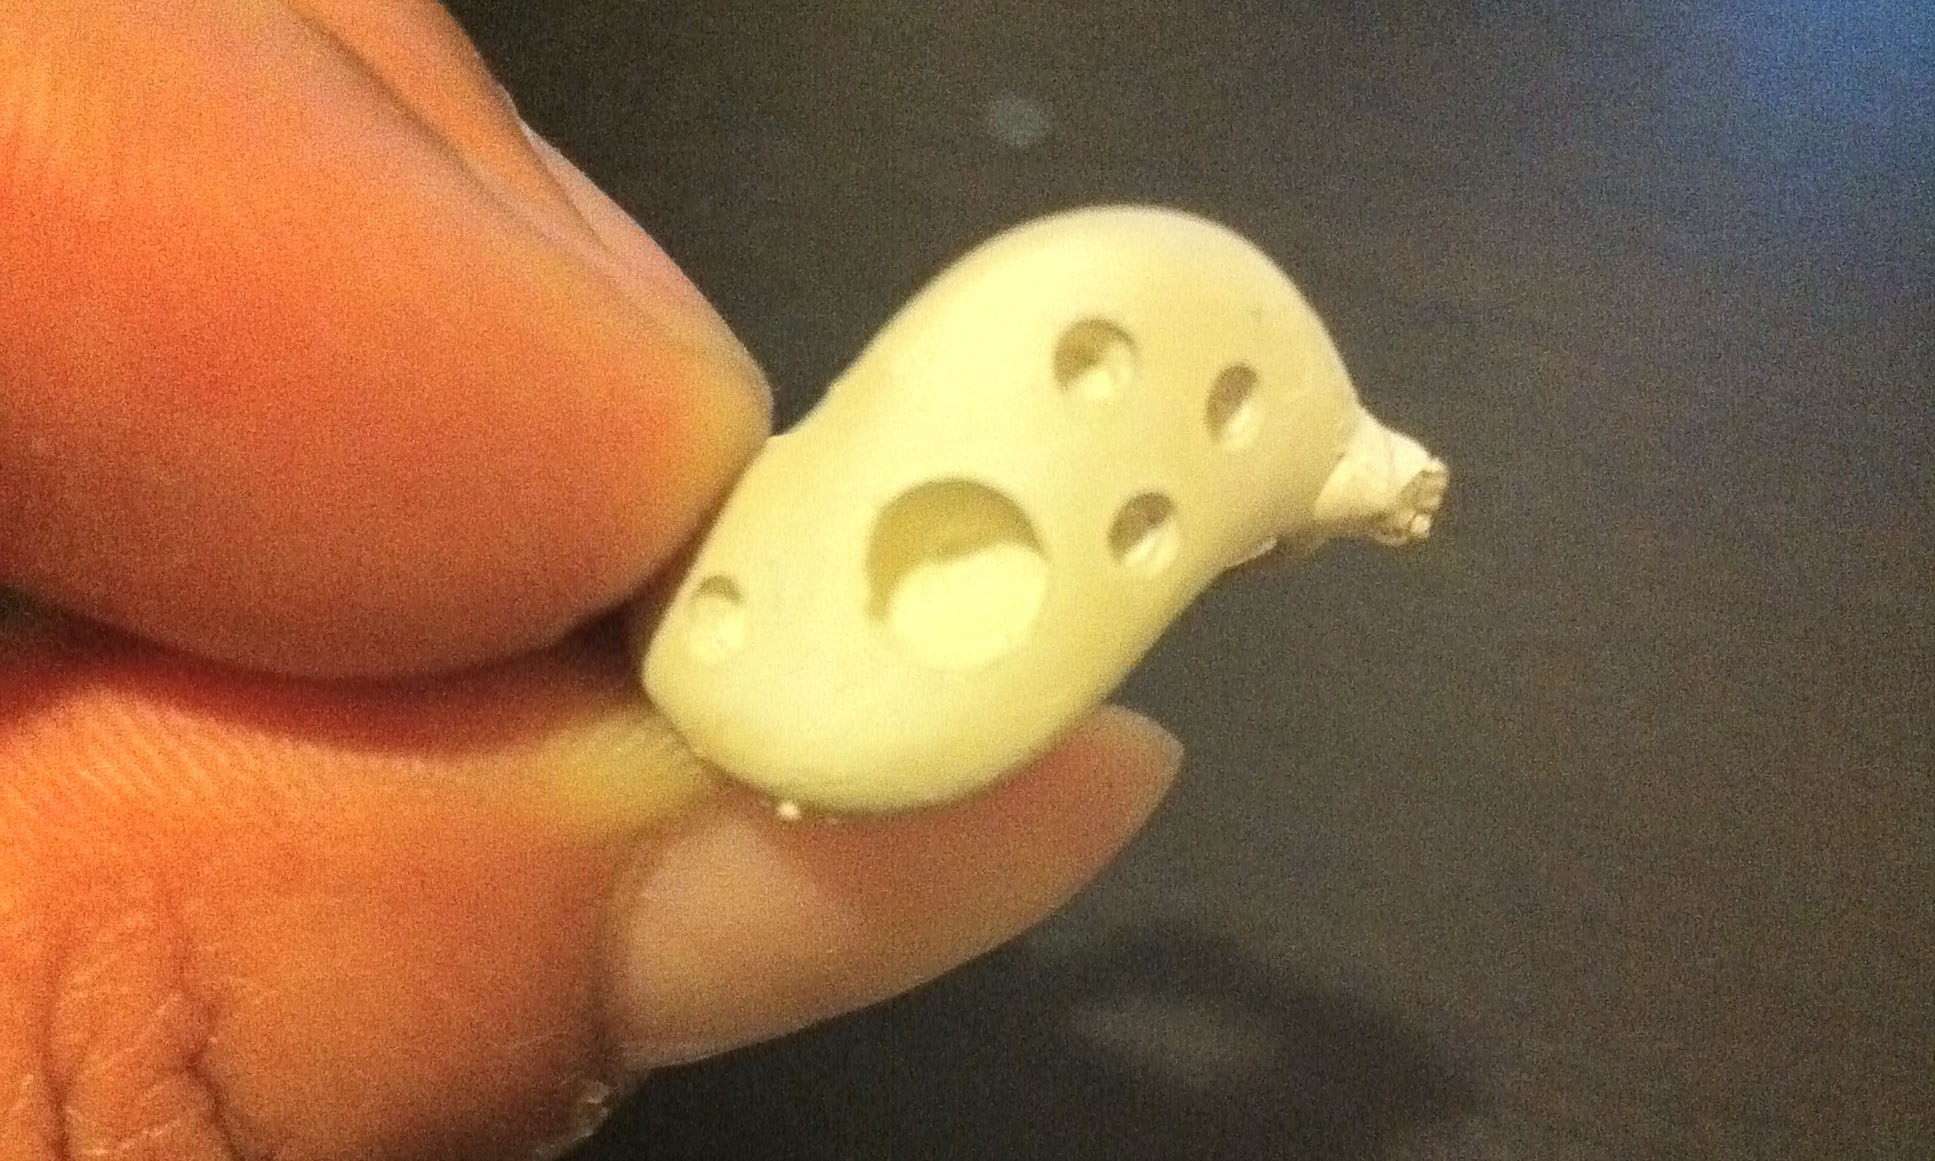
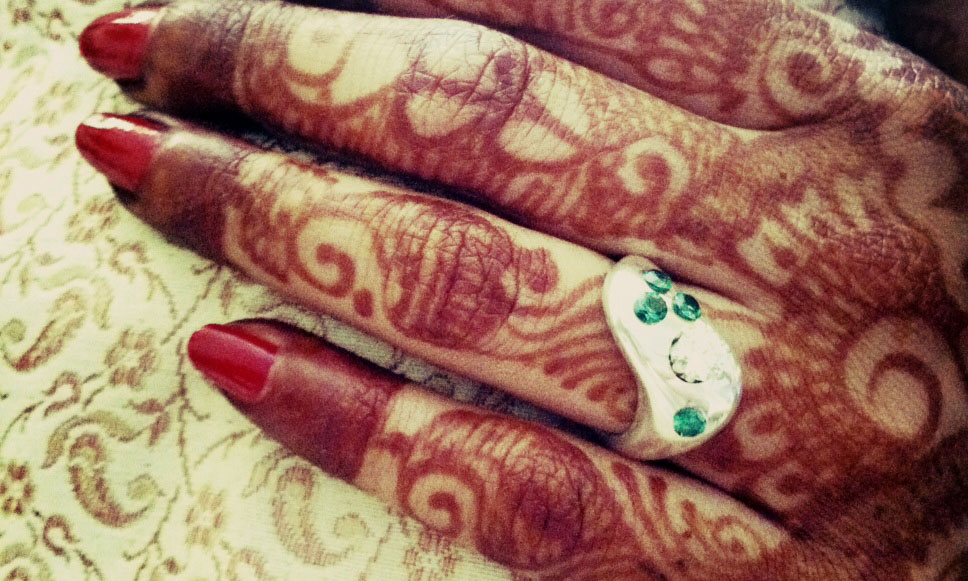
Making the engagement ring was a job for a mechanical engineer with a Master's degree. The process: sketch concepts, carve the shape out of wax and have a friend investment cast it. After sanding, polishing and installing a crown to hold the diamond, the ring was complete. And, yes, she said yes!
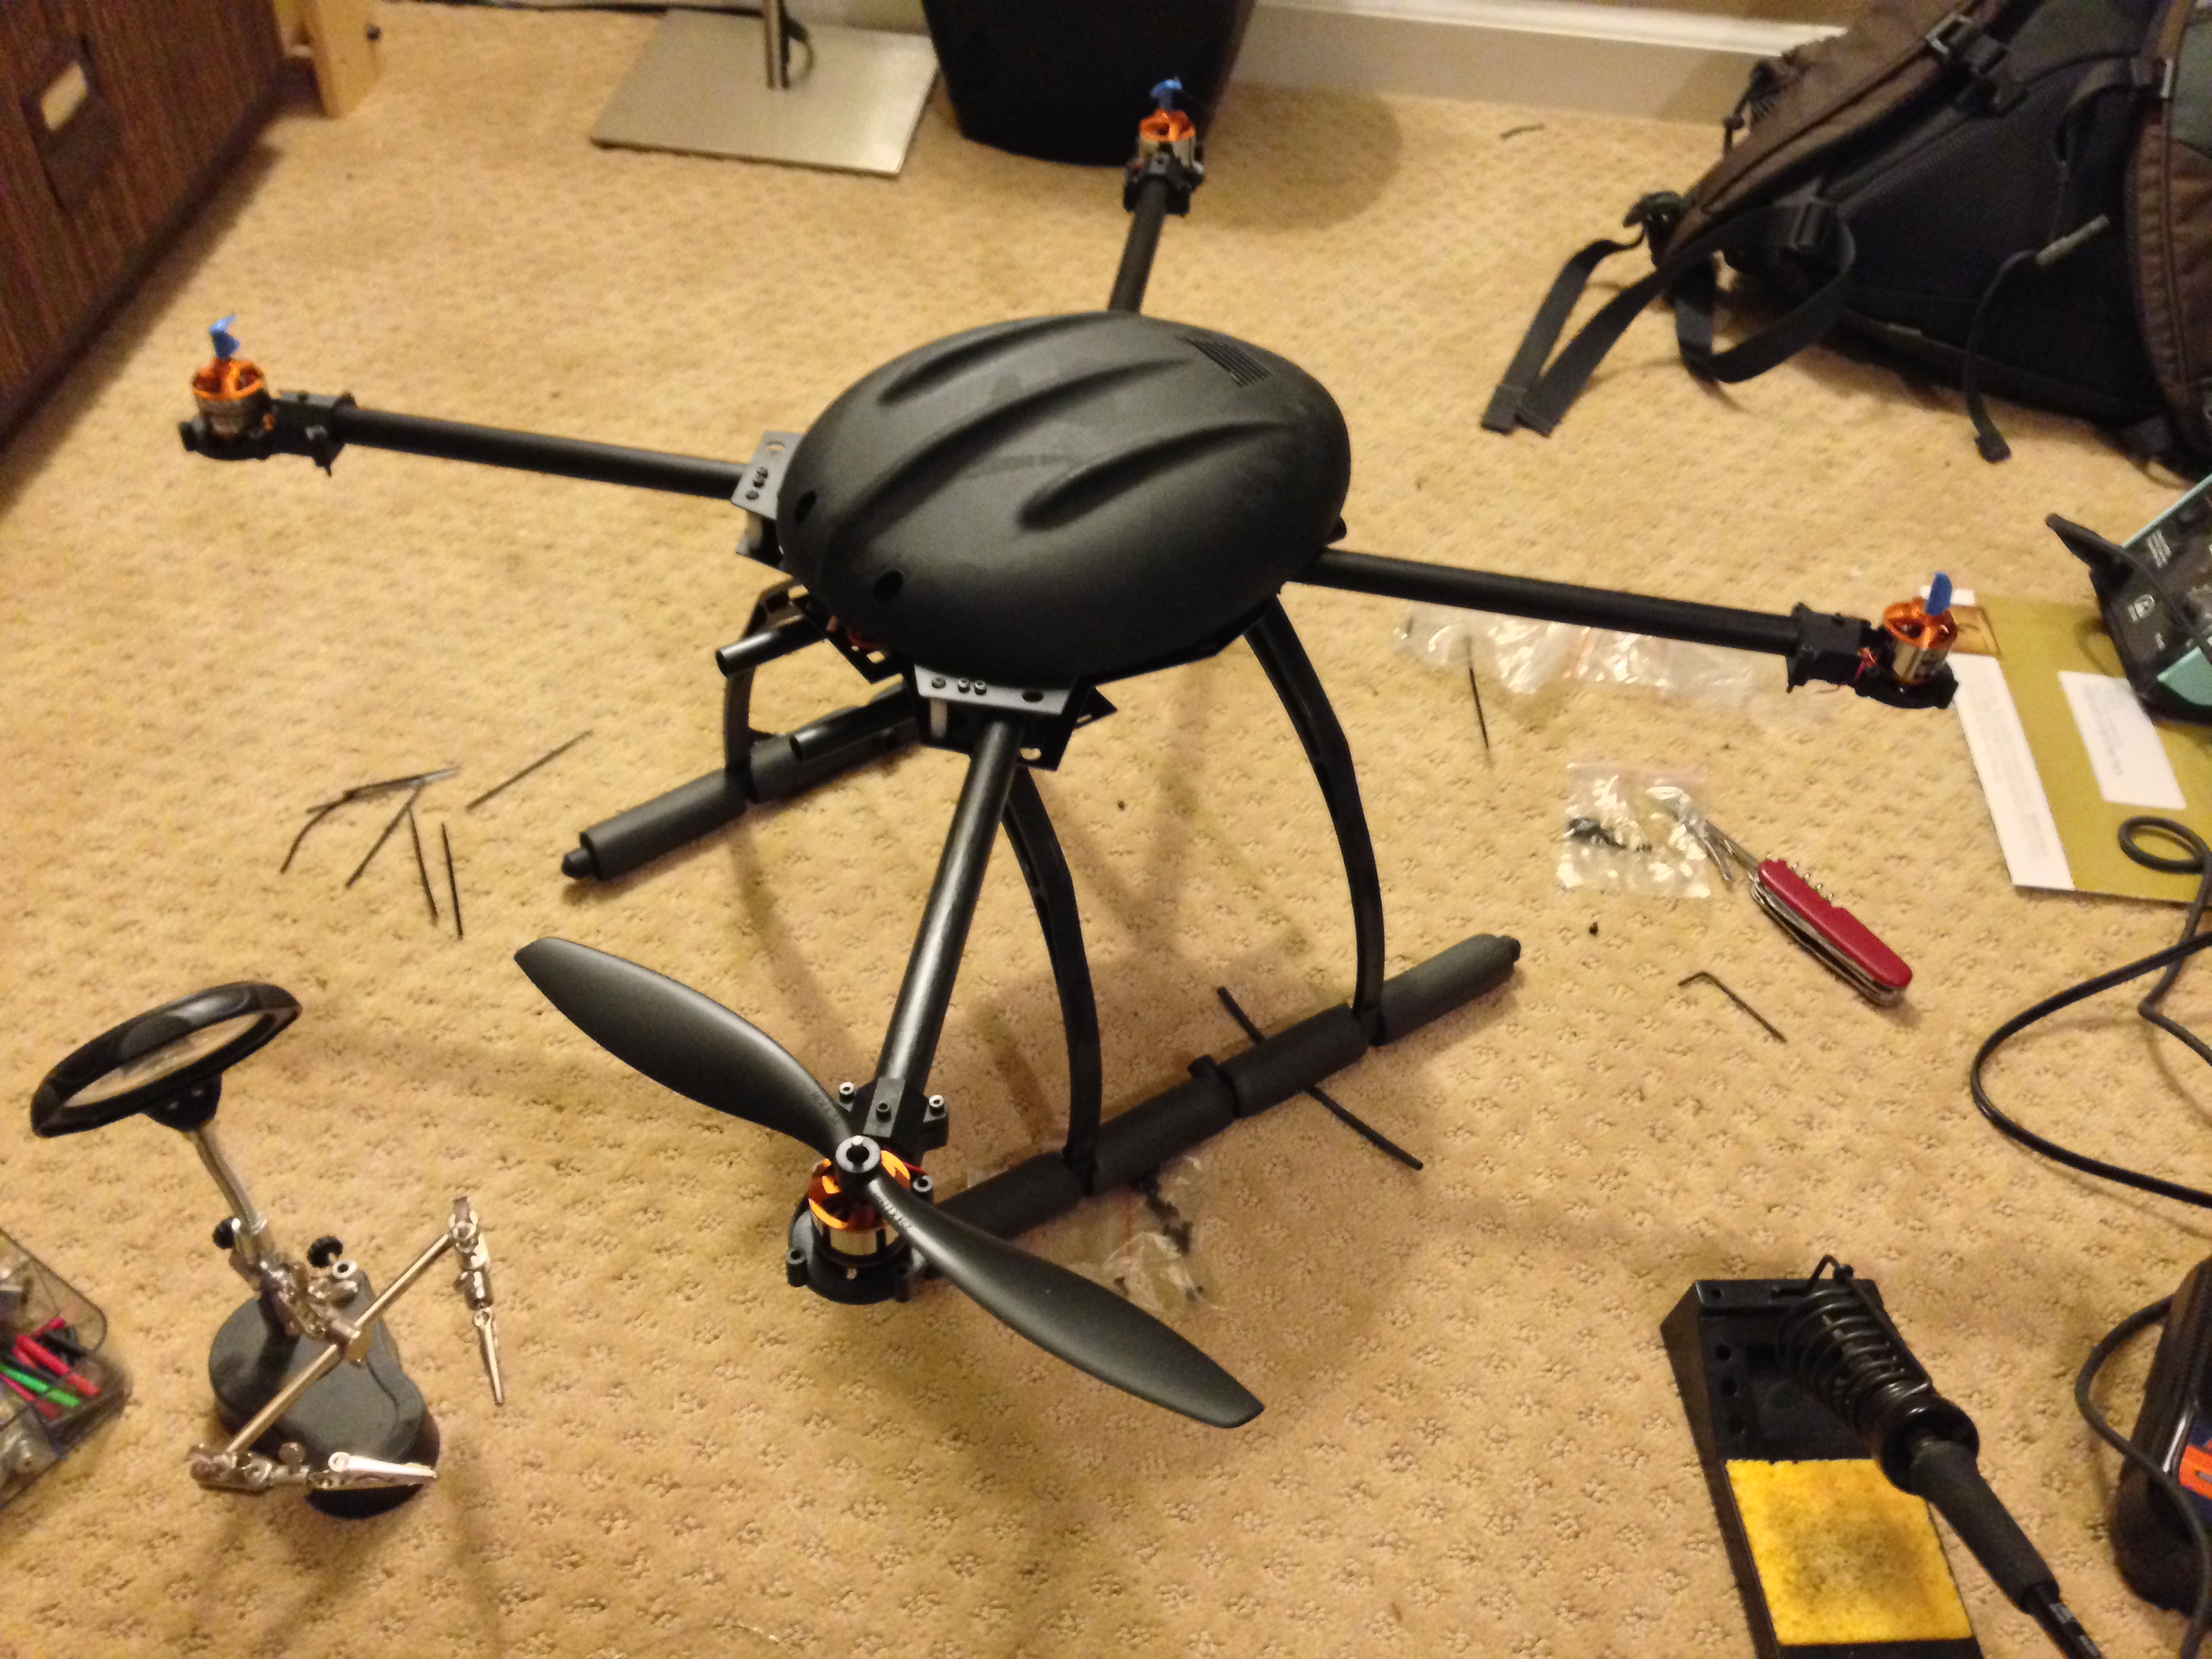
Quadcopters, or drones, are extremely fun to design, build and fly. A few years ago, a couple of friends and I got pretty into them. Designed and built a few frames and quadcopters. Also built a prototype vibration-damped gimbal for stabilized video with a GoPro on one of the bigger frames.